USD
 INR
Call Us Now
+91 9106756572
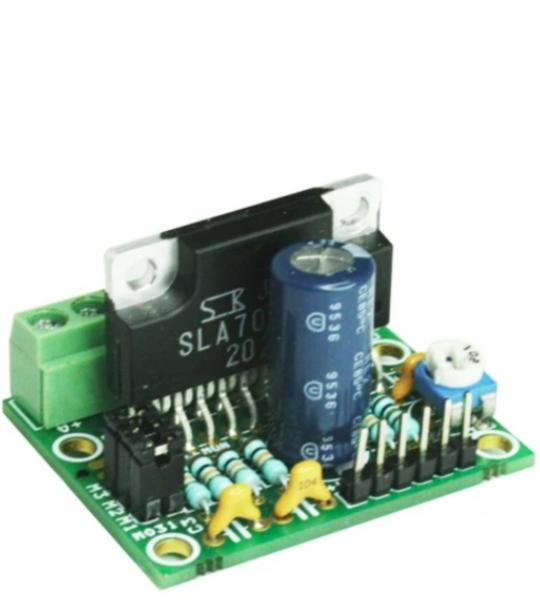
This tiny Unipolar stepper motor driver has been designed around SLA7078MPR IC from Sanken. It is a unipolar stepper Motor driver that can handle current up to 3 Amps and has micro-stepping up to 1/16 steps. On-board Jumpers are available to set the Micro-stepping and Preset (Potentiometer) to set the current.
The SLA7078MPR series motor driver ICs features unipolar drivers. The clock-in type input interface allows simplified control logic, and options for built-in sense current detection and load circuit short or open protection (patent pending) provide lower loss, and lower thermal resistance.
The built-in excitation distribution circuit (sequencer) allows motor control using only the CLOCK signal for simple operations (rotate/stop), with motor speed control by frequency input into CLOCK pin. This eliminates logic signal lines required for conventional phase-input methods, and reduces demand on heavily-used CPUs.
Unipolar stepper board is a high efficient stepper driver for Unipolar stepper motor and it has been designed for various application like robotics, control routers, lathes, mills, PCB drillers and engravers.
This board has been designed to be used in two ways, Stand Alone and Microcontroller Interface or Auto Half Current.
Just to Rotate Motor normally bellow inputs required:
For Micro-Controller Interface or Auto Half Current (while Motor is in Hold-State):
Usually In Motion control and CNC application stepper motor driver required auto Half Current function specially while motor is not moving and it’s in hold-state. For this operation SYNC and Ref required input signal.
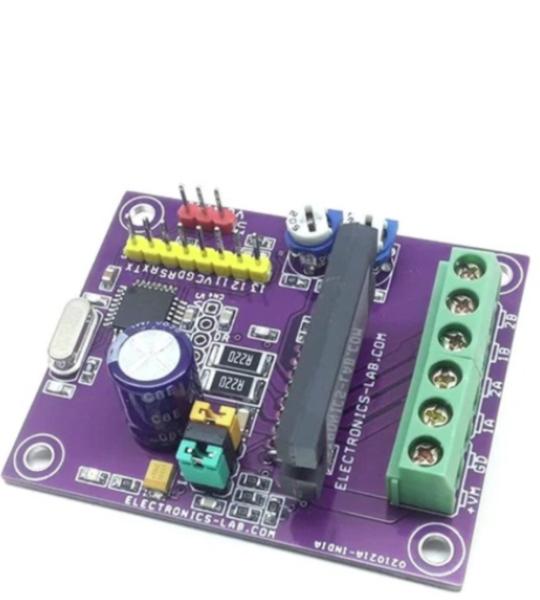
This is an Arduino compatible board that contains an Atmega328 microcontroller and Bipolar Stepper Motor Driver chip STK682-010. This Hybrid IC from ON Semiconductor can deliver up to 2.5A current and it can have an input supply up to 32V DC. It has multiple micro-stepping options such as Full step, 1/2th Step, 1/4th Step, 1/8th Step, 1/16th Step, 1/32th Step, 1/64th Step, 1/128th Step. PR1 trimmer potentiometer is provided to set the decay, 3.5V Slow Decay, 1.1V to 3.1V Mixed Decay, 0.8V-1V Fast Decay, and PR2 Trimmer Potentiometer provided to set the output current. Chopping frequency set to 83.3 Khz using capacitor C5 100PF. Micro-Stepping can be set with the help of jumper J1, J2, J3. This board is by default enabled since the enable pin has a pull-up resistor, but you can provide a low signal to disable the motor driver chip. Atmega328D provides Direction pulse, Step pulse, Enable control, etc. The IC has built-in automatic half current functions to reduce the vibrations & current while the motor is in static mode. It is important to use a heatsink on the motor driver chip. Refer to the micro-stepping table to set the micro-stepping. Board requires a Motor power supply as well logic supply 5Vdc.
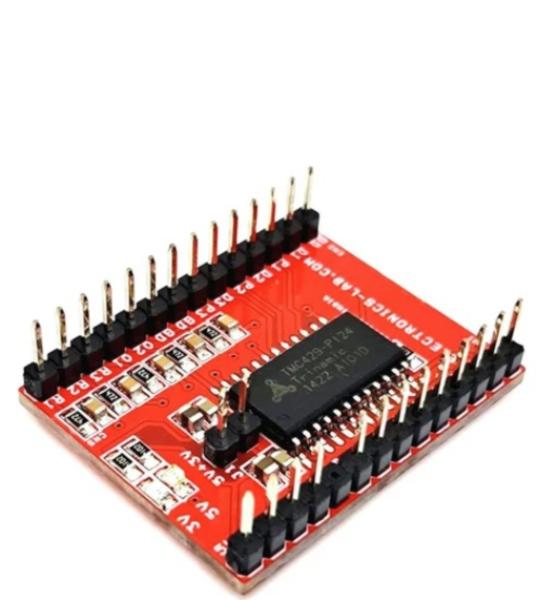
This TMC429 Breakout Board is a versatile motion control solution that enables users to create sophisticated three-axis motion control systems. This board interfaces with the TMC429 chip through SPI communication and provides 3-axis step/direction output signals along with limit switch inputs.
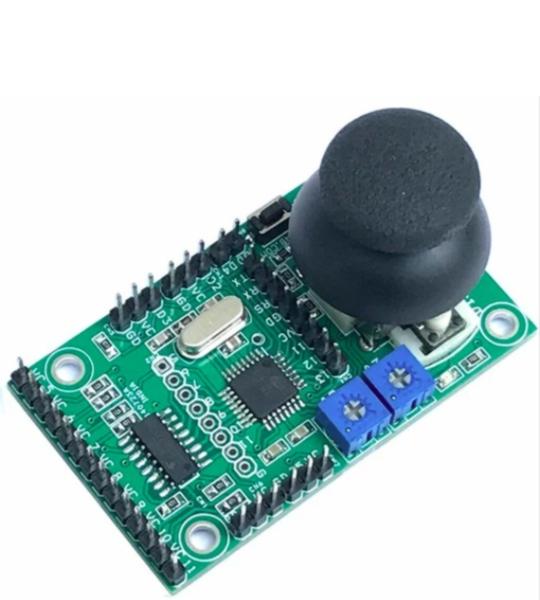
This is a pulse generator for a stepper motor driver using a joystick. It is a board that contains an Arduino-compatible microcontroller and circuitry for controlling up to 2-channel (2-axis) stepper motors. The board has multiple options to develop stepper motor-related control systems, from a 2-axis analog joystick to a trimmer potentiometer to a 7-channel open collector TTL output to interface stepper drivers with optocoupler inputs, etc.
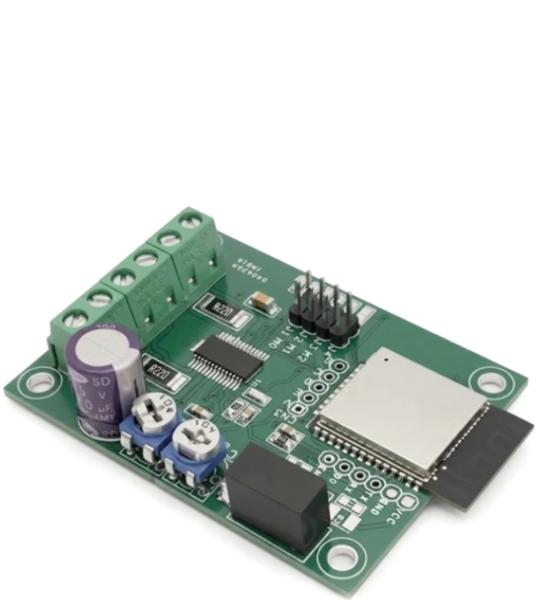
This Wi-Fi Stepper Motor Driver enables remote control of a bipolar stepper motor over a wireless network. The project is based on the ESP32 Wi-Fi microcontroller and the BD63731EFV stepper motor driver IC, providing a compact and reliable solution for motion control applications.
The driver operates from a 24 VDC power supply and is capable of driving bipolar stepper motors with output currents of up to 3A. The BD63731EFV supports multiple micro-stepping modes, allowing smooth and precise motor operation while reducing vibration and audible noise.
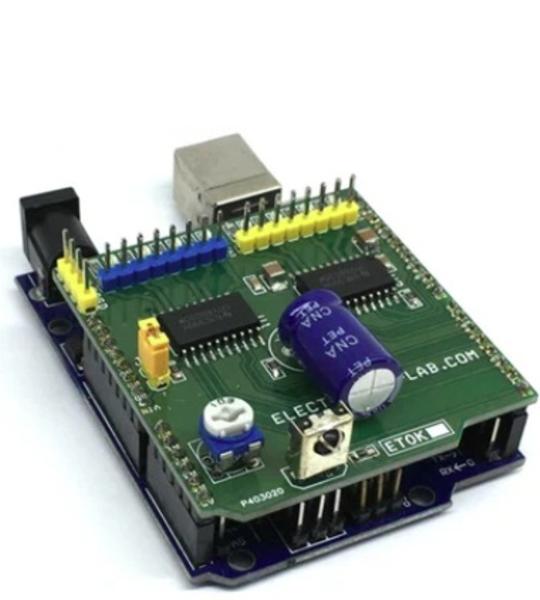
The 8 Channel Driver Arduino UNO Shield is designed to enable users to switch inductive loads for up to 800mA each channel and up to 24V DC with no heat-sink needed. It is ideal for such applications as driving 2x unipolar stepper motors, solenoids, relays, and small DC motors. It uses 2x DRV8803 Chip from Texas instruments which is 4 channel low side driver with over current protection. IC’s Internal shutdown protection function is provided for overcurrent protection, short circuit protection, under-voltage lockout, and over temperature. Faults are indicated by a fault output pin that is normally high and goes low if a fault condition occurs. Reset and enable pins has internal pull-down resistors.
Cookie preferences