USD
 INR
Call Us Now
+91 9106756572
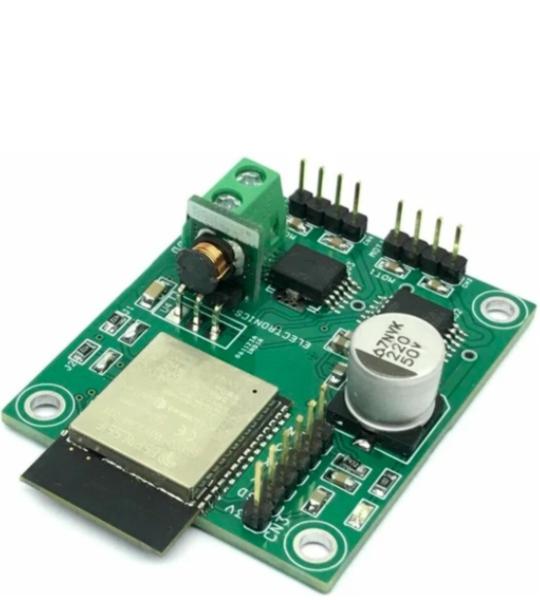
This wireless robot car controller board is built using an ESP32 BT/Wi-Fi module, 2 x H-Bridges, 3.3V regulator. It also includes an ESP32 programming connector, power LED, screw terminal connector for the power supply, header connector for motors, and high-value capacitors on the DC supply for smooth motor operations. The operating power supply is 8V to 24V DC. The project has two H-brides and each can drive 2.5A continues. The board is suitable for small and medium-sized robot cars. It is an open-source hardware project that can be programmed as per requirement. ESP32 I/O details are available in descriptions. ESP32 supports Bluetooth connectivity and the robot car can be controlled using a small phone, Laptop, or Tablet. The project was built using an ESP32-Wroom processor and this chip supports Bluetooth and Wi-Fi connectivity.
This wireless robot car controller board is built using an ESP32 BT/Wi-Fi module, 2 x H-Bridges, 3.3V regulator. It also includes an ESP32 programming connector, power LED, screw terminal connector for the power supply, header connector for motors, and high-value capacitors on the DC supply for smooth motor operations. The operating power supply is 8V to 24V DC. The project has two H-brides and each can drive 2.5A continues. The board is suitable for small and medium-sized robot cars. It is an open-source hardware project that can be programmed as per requirement. ESP32 I/O details are available in descriptions. ESP32 supports Bluetooth connectivity and the robot car can be controlled using a small phone, Laptop, or Tablet. The project was built using an ESP32-Wroom processor and this chip supports Bluetooth and Wi-Fi connectivity.
The project can be tested with example Arduino code which is provided below. The user will be able to drive a robot car with a PS3 Bluetooth remote. Refer to the link below to learn more about PS3 and ESP32 pairing, and ESP32 programming under Arduino IDE.
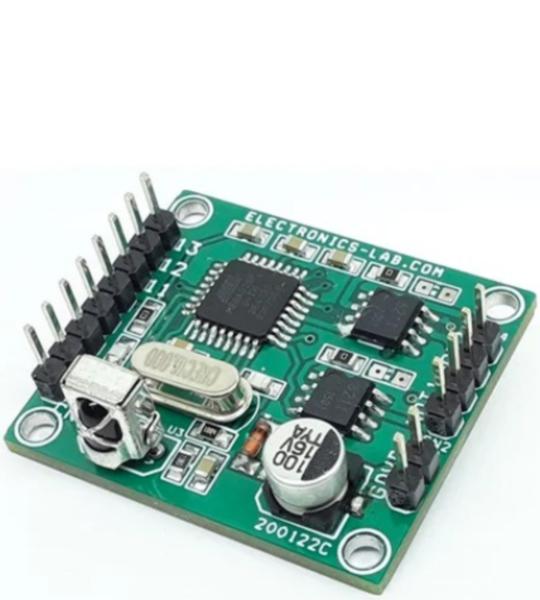
The Robot Controller is a very compact solution for controlling small and medium size robots using an Infrared remote. The project is fully Arduino compatible and consists of an ATMEGA328 microcontroller, 2 x BD6211 motor drivers, TSOP1838 IR sensor. BD6211 H-bridge is a full bridge driver for brush motor. The reference pin of BD6211 is pulled high and needs 2 x input to control the direction of the motor. 2 input pins of BD6211 are connected to ATMEGA328 for direction control of the motor. The project can be used to drive dual motors for 3-wheel robots or 4 x mini-DC motors. Input power supply 4.5V to 5.5V DC, the project can drive load up to 1A for each channel. Connector CN1 is provided to program the ATMEGA328 chips using Arduino IDE.
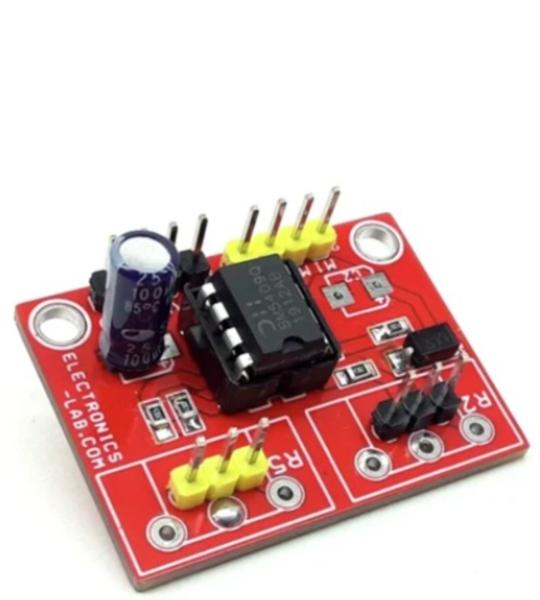
This is a low-cost position control closed-loop analog-servo using brushed DC motor and potentiometer as feedback. This product provides all necessary active functions for a closed-loop servo system using a Brushed DC Motor and potentiometer mounted on the output shaft of the DC Motor with Gear. The module is ideally suited for almost any servo positioning application. Can be used in applications such as side mirror movement control for cars, car head lamp beam control, animatronics, robotics, etc.
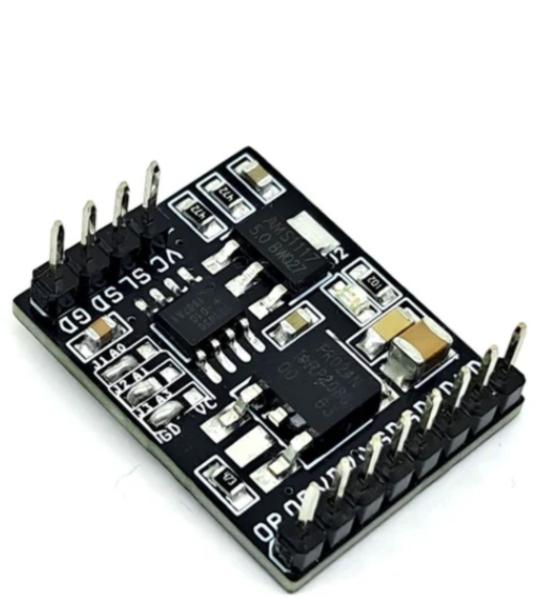
This project is based on the DS1050 chip, a 5-bit pulse-width modulator (PWM) controlled via a 2-wire (I²C) interface. The 2-wire bus allows a single master device to control up to eight slave devices (DS1050 or other compatible 2-wire peripherals). The project consists of a DS1050 I²C PWM generator combined with a MOSFET stage capable of driving high-current loads. It is primarily designed for driving LEDs and resistive loads, but it can also be used with inductive loads when an external flyback diode is added to protect against back-EMF.
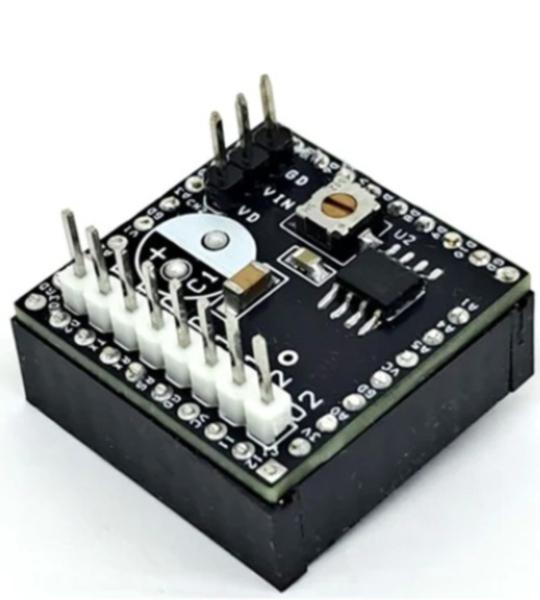
This power driver shield is designed to drive solenoids or brushed DC motors using the OLEDUINO-V2 platform. The driver can handle peak currents of up to 3.7A and supports a DC supply voltage of up to 24Vdc.
The PWM interface can be used to drive single-coil relays, Dual coil relay, solenoids and DC brushed motor. To actuate a load the driver must supply current in either the forward or reverse state as defined in the PWM control table.
After actuation, the outputs can be disabled (IN1 = IN2 = 0) to place the driver in sleep mode and reduce power consumption. Alternatively, the outputs can be briefly set to brake mode after actuation to suppress back-EMF effects from the relay and prevent current from flowing back into the VM supply node.
When using the DRV8231 device, an external current-sense resistor is required; a 0.22 Ω, 2 W, 1% SMD 2512 resistor is recommended.
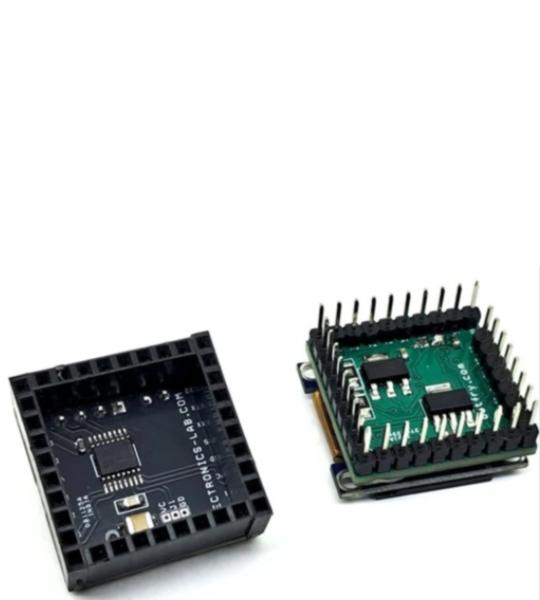
This multi-purpose motor driver shield is built around the BD60210FV motor driver IC. It is designed specifically for the OLEDUINO-V2 board, which features an onboard OLED display. This compact shield can be used to drive small bipolar stepper motors, two bidirectional brushed DC motors, and 4 solenoids.
The shield is capable of driving two brushed DC motors up to 1A continuous current with a supply voltage range of 8 V to 12 V. A key advantage of this shield is its seamless integration with the OLEDUINO-V2, allowing real-time display of speed, direction, and other operational information.
Cookie preferences